# ITK ERROR: MattesMutualInformationImageToImageMetricv4(000002CDB6B52D80): ....
**URL:** https://discourse.itk.org/t/itk-error-mattesmutualinformationimagetoimagemetricv4-000002cdb6b52d80/5746
**Category:** Uncategorized
**Created:** [February 22, 2023, 9:29pm UTC](https://discourse.itk.org/t/itk-error-mattesmutualinformationimagetoimagemetricv4-000002cdb6b52d80/5746 "2023-02-22T21:29:16Z")
**Posts on this page:** 3
**Page:** 1
### Author:  [@banikr](https://discourse.itk.org/u/banikr)
#### Post date: [February 22, 2023, 9:29pm UTC](https://discourse.itk.org/t/itk-error-mattesmutualinformationimagetoimagemetricv4-000002cdb6b52d80/5746/1 "2023-02-22T21:29:16Z")
I am trying to register a segmented image on an MR image.
```auto
image shapes: (22, 20) (22, 20)
```
The MR image has intensity normalized from 0-1. The segmentation map has labels from 0-3(0 - background).
Both images need some rotational reorientation,
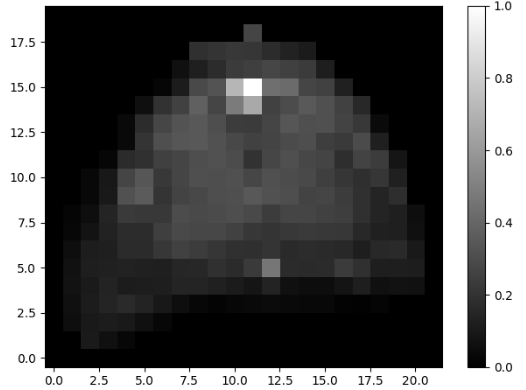
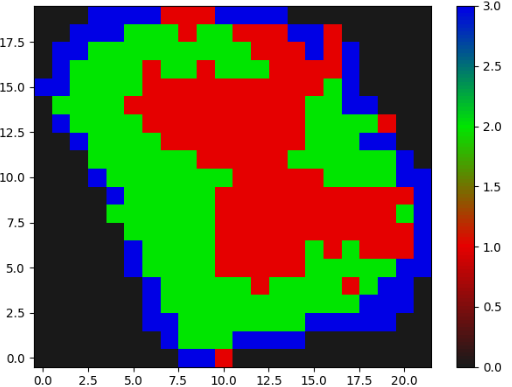
as can be seen above.
So I wanted to perform Euler transformation before delving into any non-rigid transformation.
I am using the following codes to do that:
```auto
mrItk = sitk.GetImageFromArray(mrImgNorm)
segItk = sitk.GetImageFromArray(secImg_resized)
fixed_image = sitk.Cast(mrItk, sitk.sitkFloat32)
moving_image = sitk.Cast(segItk, sitk.sitkFloat32)
print("image shapes: ", fixed_image.GetSize(), moving_image.GetSize())
all_orientations = np.linspace(-2 * np.pi, 2 * np.pi, 100)
# print(all_orientations)
# Evaluate the similarity metric using the rotation parameter space sampling, translation remains the same for all.
initial_transform = sitk.Euler2DTransform(sitk.CenteredTransformInitializer(fixed_image,
moving_image,
sitk.Euler2DTransform(),
sitk.CenteredTransformInitializerFilter.GEOMETRY))
# Registration framework setup.
registration_method = sitk.ImageRegistrationMethod()
registration_method.SetMetricAsMattesMutualInformation(numberOfHistogramBins=500)
registration_method.SetMetricSamplingStrategy(registration_method.RANDOM)
registration_method.SetMetricSamplingPercentage(0.001)
registration_method.SetInitialTransform(initial_transform, inPlace=False)
registration_method.SetOptimizerAsRegularStepGradientDescent(learningRate=2.0,
minStep=1e-4,
numberOfIterations=500,
gradientMagnitudeTolerance=1e-8)
registration_method.SetInterpolator(sitk.sitkNearestNeighbor)
registration_method.SetOptimizerScalesFromIndexShift()
# best_orientation = (0.0, 0.0)
best_similarity_value = registration_method.MetricEvaluate(fixed_image, moving_image)
similarity_value = []
# Iterate over all other rotation parameter settings.
for key, orientation in enumerate(all_orientations): # .items():
initial_transform.SetAngle(orientation)
registration_method.SetInitialTransform(initial_transform)
current_similarity_value = registration_method.MetricEvaluate(fixed_image, moving_image)
similarity_value.append(current_similarity_value)
# print("current similarity value: ", current_similarity_value)
if current_similarity_value <= best_similarity_value:
best_similarity_value = current_similarity_value
best_orientation = orientation
# else:
# best_orientation = orientation
print('best orientation is: ' + str(best_orientation))
print(current_similarity_value)
plt.plot(all_orientations, similarity_value, 'b')
plt.plot(best_orientation, best_similarity_value, 'rv')
plt.show()
initial_transform.SetAngle(best_orientation)
registration_method.SetInitialTransform(initial_transform, inPlace=False)
eulerTx = registration_method.Execute(fixed_image, moving_image)
resampler = sitk.ResampleImageFilter()
resampler.SetReferenceImage(fixed_image)
resampler.SetInterpolator(sitk.sitkNearestNeighbor)
resampler.SetDefaultPixelValue(0)
resampler.SetTransform(eulerTx)
out = resampler.Execute(moving_image)
displayImage(sitk.GetArrayFromImage(out), Title_='registered image(Euler2D)')
displayImage(sitk.GetArrayFromImage(moving_image), Title_='moving image')
displayImage(sitk.GetArrayFromImage(fixed_image), Title_='fixed image')
checkerImg = compare_images(sitk.GetArrayFromImage(out),
sitk.GetArrayFromImage(fixed_image),
method='diff')
displayImage(checkerImg, Title_='mask-label overlapped')
del registration_method, initial_transform, eulerTx
moving_image = sitk.Cast(out, sitk.sitkFloat32)
```
but I am getting this error at this line here:
```auto
ITK ERROR: MattesMutualInformationImageToImageMetricv4(00000207A2415B70): VirtualSampledPointSet must have 1 or more points.
```
```auto
eulerTx = registration_method.Execute(fixed_image, moving_image)
```
From a previous discussion here, I thought the image size must be equal for both the images, that is why I mentioned them here.
To some extent plotting the metric makes sense:
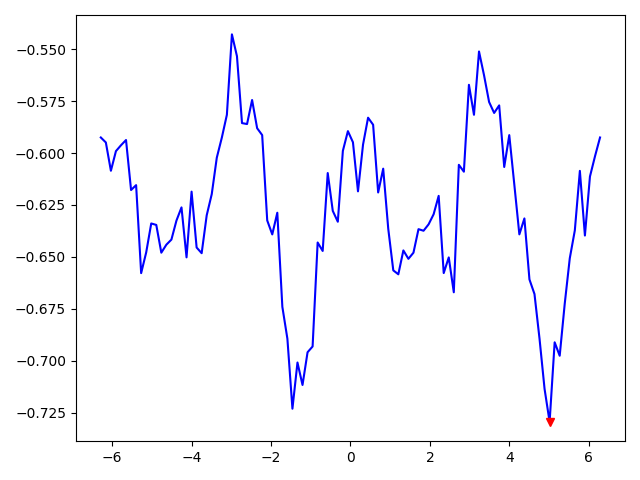
because at `best_orientation` (the red marker) the moving image seems to be somewhat matching with MR:
```auto
rotated_segmentation = ndimage.rotate(secImg_resized, np.rad2deg(best_orientation))
displayImage(rotated_segmentation, Title_='rotated sec')
```
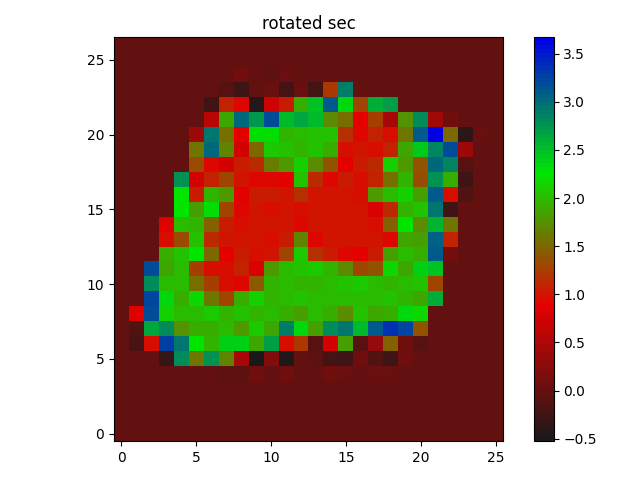
Obviously, the labels are changed, but this is not registered anyway, just rotating the image using `ndimage` simply.
what shall I do from here?
---
### Author:  [@banikr](https://discourse.itk.org/u/banikr)
#### Post date: [February 23, 2023, 12:21am UTC](https://discourse.itk.org/t/itk-error-mattesmutualinformationimagetoimagemetricv4-000002cdb6b52d80/5746/2 "2023-02-23T00:21:41Z")
> [@banikr](#):
>
> `registration_method.SetMetricSamplingStrategy(registration_method.RANDOM)`
changing this to:
```auto
registration_method.SetMetricSamplingStrategy(registration_method.NONE)
```
runs the registration.
Though it is mentioned in the documentation:
> Sampling strategies for obtaining points.
> **NONE** : use all voxels, sampled points are the voxel centers.
> **REGULAR** : sample every n-th voxel while traversing the image in scan-line order, then within each voxel randomly perturb from center.
Now I haven’t completed the registration or performance, but is it the right method to solve the error?
---
### Author:  [@zivy](https://discourse.itk.org/u/zivy)
#### Post date: [February 23, 2023, 1:03am UTC](https://discourse.itk.org/t/itk-error-mattesmutualinformationimagetoimagemetricv4-000002cdb6b52d80/5746/3 "2023-02-23T01:03:07Z")
Hello @banikr,
Yes. In your case, with tiny images (20x18), you should not do any sort of sampling.
Also, mixing and matching between ITK/SimpleITK and scipy transformations/resampling is not recommended. Stick with one framework. With respect to your code, when you resample a label image, use nearest neighbor interpolation so that you do not introduce labels that previously did not exist (this is what happened when you used linear interpolation).
Nearest neighbor in scipy:
```auto
rotated_segmentation = ndimage.rotate(secImg_resized, np.rad2deg(best_orientation), order=0)
displayImage(rotated_segmentation, Title_='rotated sec')
```